Products
Main lines: Unitree, AgiBot, ENGINEAI — humanoids, quadrupeds, wheeled robots and robotic arms, new and pre-owned. Joint motors, joint modules and dexterous hands are also available for teams building their own robots.
Prices are confirmed per inquiry — request a quote and we confirm price, stock and lead time, usually within 24 hours. Beyond the models listed here, we can also supply any other robot made in China: if there is a model you are looking for, just let us know and we will check it for you.
Note for US visitors: for the US we offer only the models cleared for that market — ask us for the US version of this list.
Which type do you need?
Humanoid robots
Choose a humanoid when people are the point: bipedal locomotion and manipulation research, teaching, demonstrations, reception and events. If your team needs to program it, check the Development & SDK line on the model page first.
Quadruped robots
Choose a quadruped when the ground is the problem — stairs, gravel, grass and broken surfaces — for inspection work, research and field robotics.
Wheeled & wheeled-leg robots
Choose wheeled-leg when your site is mostly floors, yards and pavements but has steps or ramps: faster and longer-running on hard ground, and it can still step over obstacles.
Parts & dexterous hands
Building your own robot? Start with joint motors, joint modules and dexterous hands, quoted per specification — and ask us about matching arms, batteries and controllers.
Humanoid robots
Bipedal humanoids for research, education, exhibitions and events — new and pre-owned. Key specifications from the full catalog below; ask us for the version that fits your project.
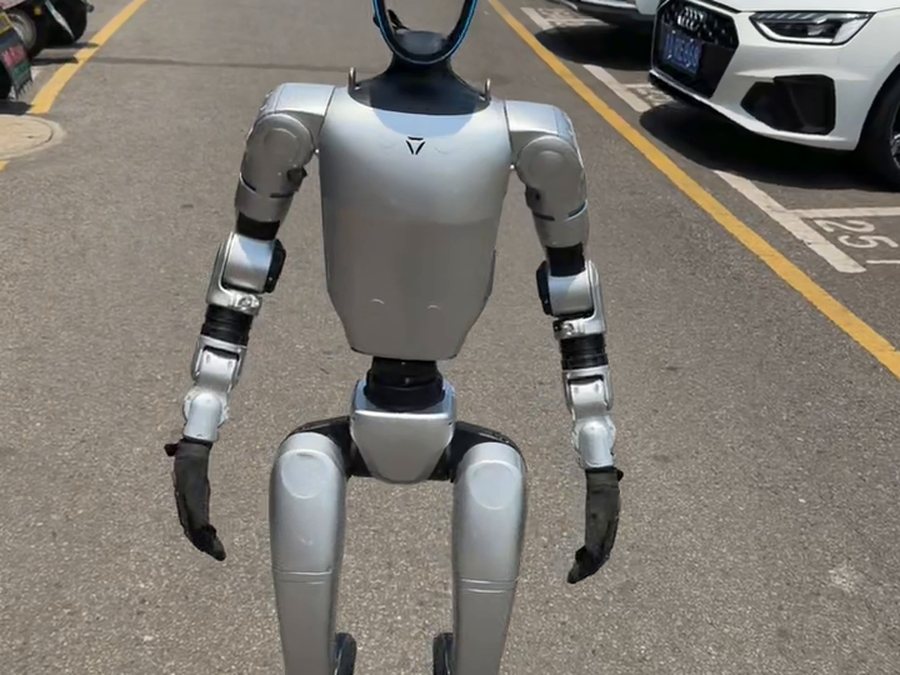
Humanoid robots are the fastest-moving part of our catalog — full-size and compact bipedal platforms for labs that need a development platform, schools that need a teaching robot, and event teams that need a crowd-puller. Most models can be supplied new or pre-owned; tell us the job the robot has to do and we will point you to the versions that fit, with the specification differences spelled out.
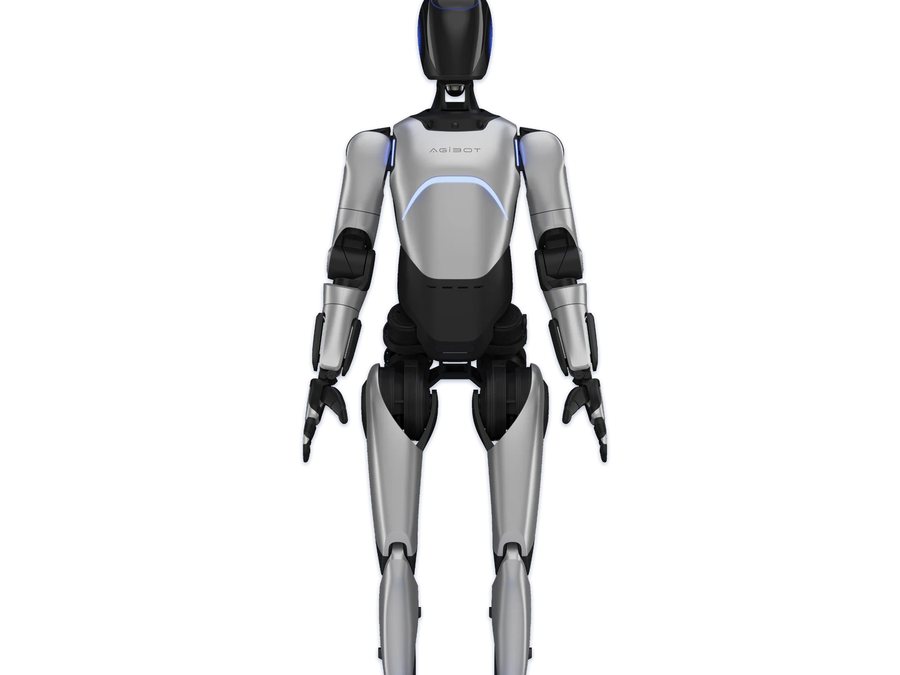
AgiBot A2
Young Edition / Flagship · New
- Size169cm (169×75×30cm)
- Weight63 kg
- DOF23
- Payload~2 kg per arm
- Battery / runtimeBattery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet)
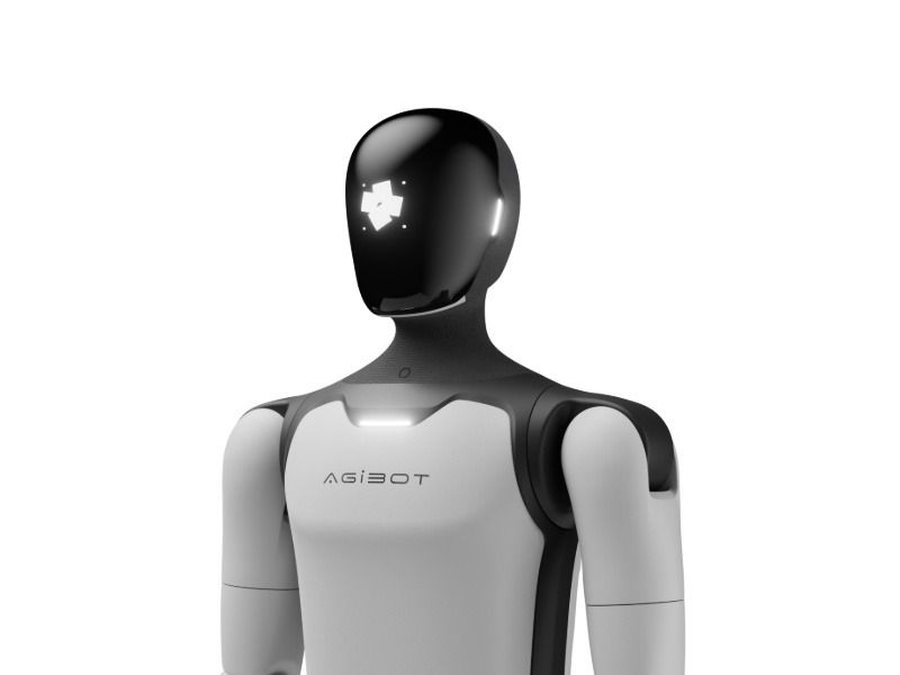
AgiBot A3
Basic Version / Development version · New
- Size173cm (173×52×30cm)
- Weight55 kg
- DOF31 (active DOF)
- Payload5 kg per arm
- Battery / runtime1152Wh dual battery; up to ~10 h in typical use (10-second battery swap)
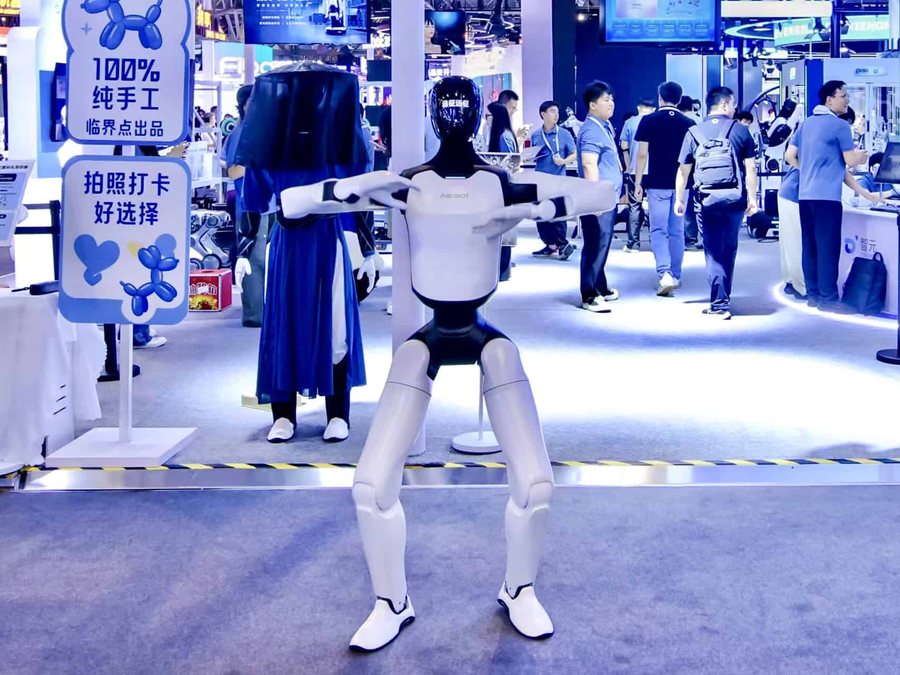
AgiBot A3 Ultra
Basic Version / Development version / Embodied version / EDU · New
- Size174cm (174×52×30cm)
- Weight60 kg
- DOF51 (active DOF)
- Payload5 kg per arm
- Battery / runtime1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap)
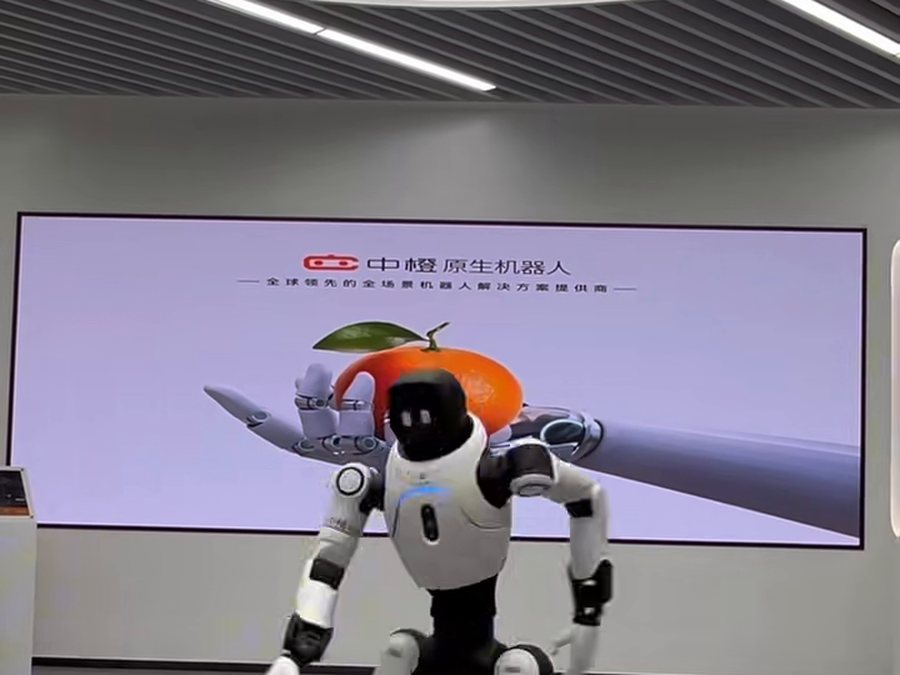
AgiBot X2
Basic Version / Ultra · Pre-owned & New
- Size131cm (131×46×21cm)
- Weight35 kg
- DOF25
- Payload~3 kg in specific postures; ≤1 kg across full workspace
- Battery / runtime~500Wh; ~2 h continuous walking (at 0.5 m/s)
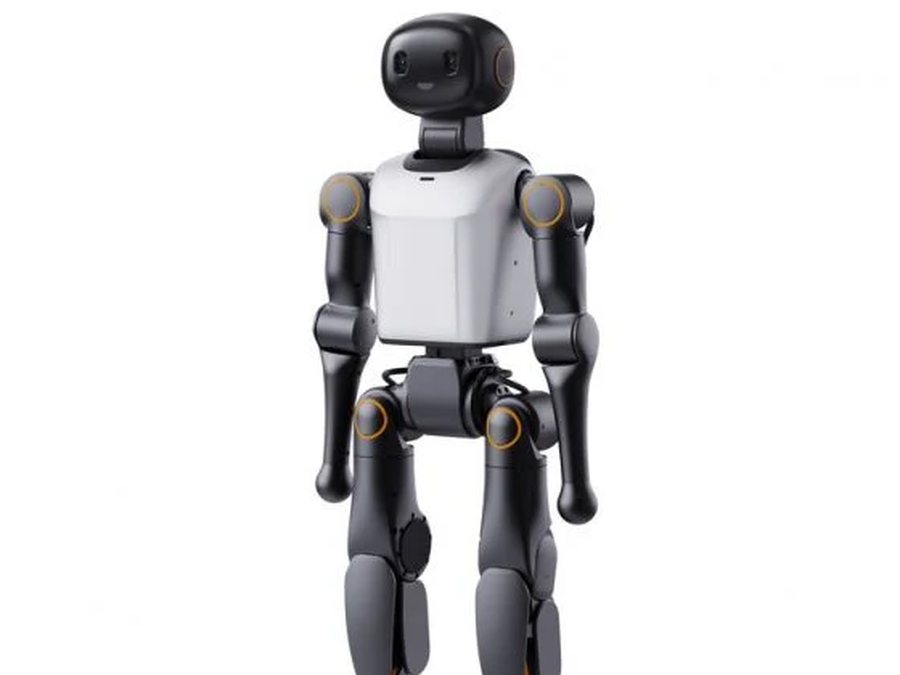
Booster K1
Geek / Education / Professional · New
- Size~95cm
- Weight19.5 kg
- DOF22
- Battery / runtime2Ah; ~20 min (official figure, walking at 1.1 m/s)
- Max speed2 m/s (walking speed per official site)
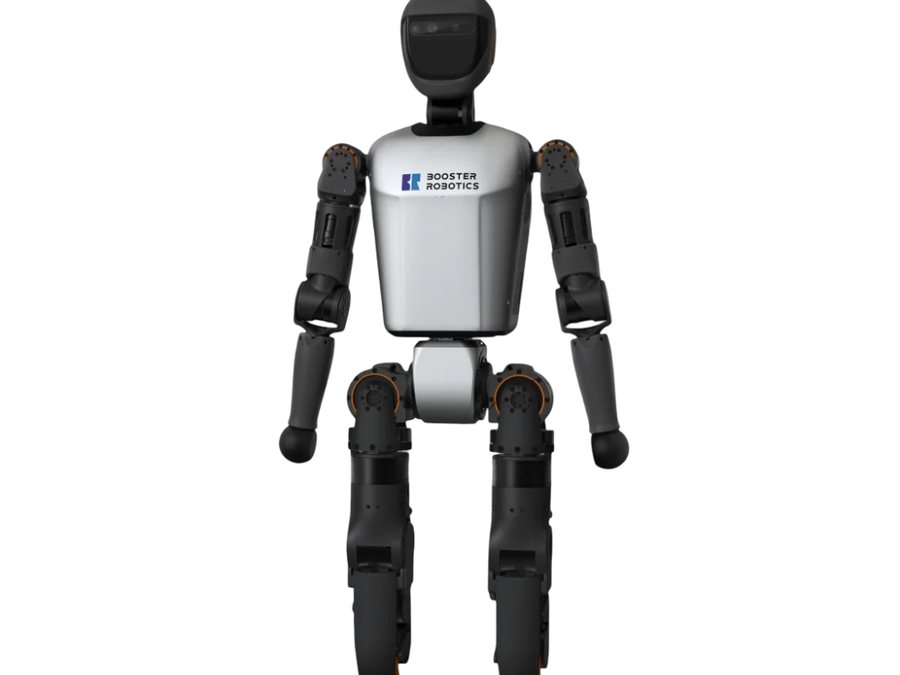
Booster T1
Basic / Standard / Customized · New
- Size118cm (118×47×23cm)
- Weight30 kg
- DOF23
- Battery / runtime10.5Ah battery; ~2 h walking, ~4 h standing
- Max speed0.5 m/s (walking speed per manual; top speed not published)
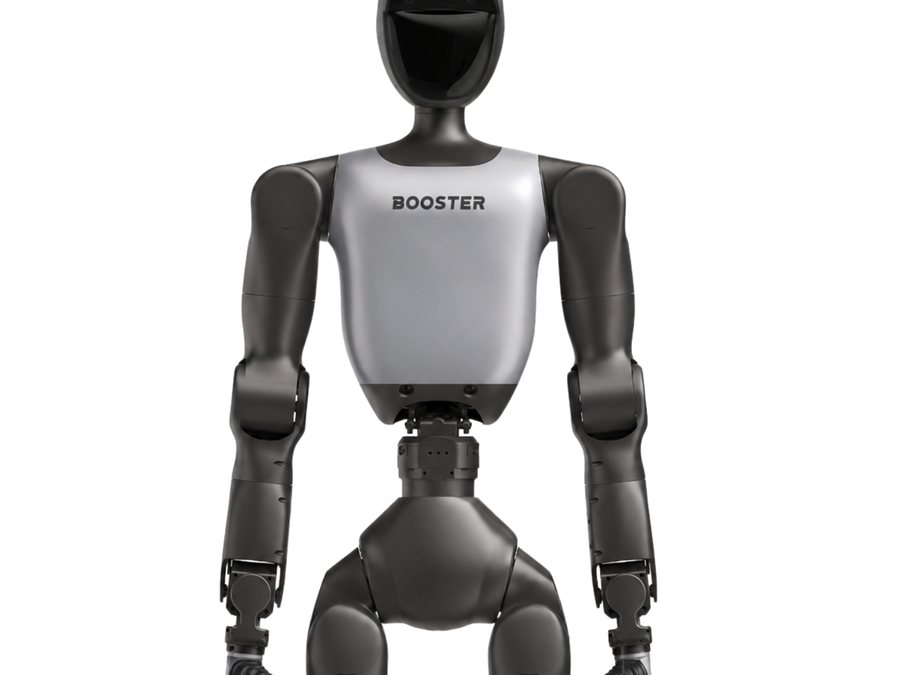
Booster T2
P1 / P2 Claw / P3 Nimble Hands · New
- Size140cm
- Weight~42 kg
- DOF31
- PayloadMax 10 kg both arms (base configuration, no end effector)
- Battery / runtime48V 10Ah; ~2 h continuous walking
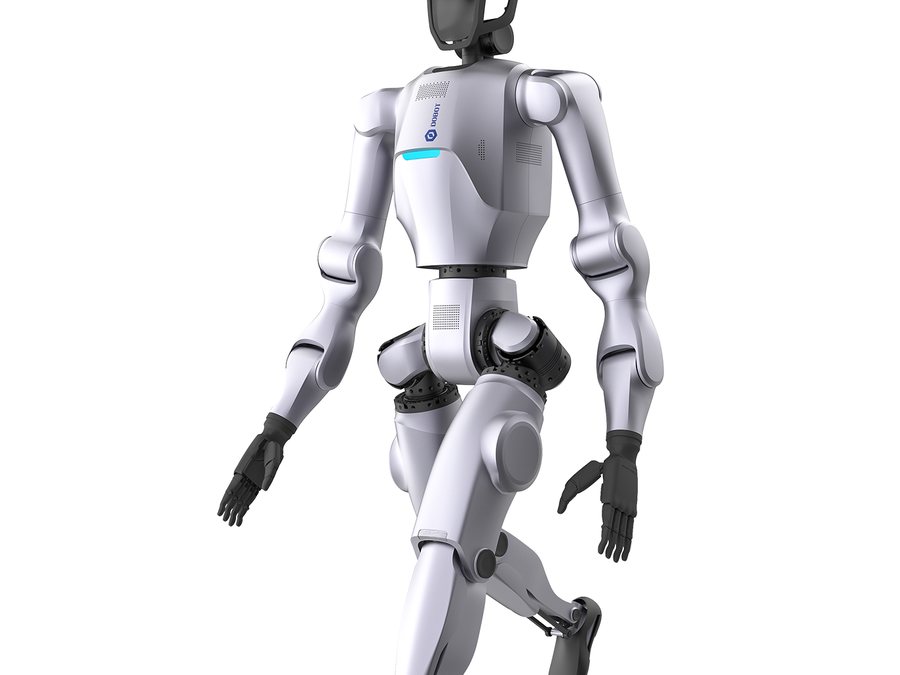
Dobot Atom
Base · New
- SizeHeight ~1530mm
- Weight62 kg
- DOF41 (incl. dexterous hands; 29 without hands)
- Payload3.5 kg per arm
- Battery / runtime~2 h
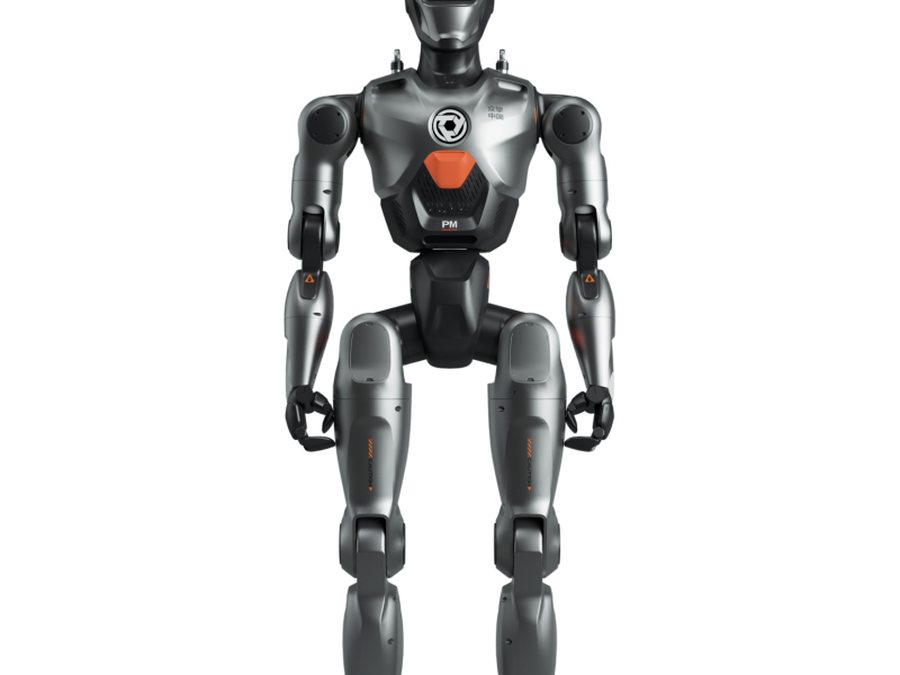
EngineAi PM01
Commercial / Education · Pre-owned
- Size138cm (manual: 1388×490×220 mm)
- Weight~40 (manual spec table ~43 incl. battery — sources differ)
- DOF23 (manufacturer headline says 24-DOF)
- Battery / runtime~2 h (10,000mAh quick-release battery)
- Max speed2m/s
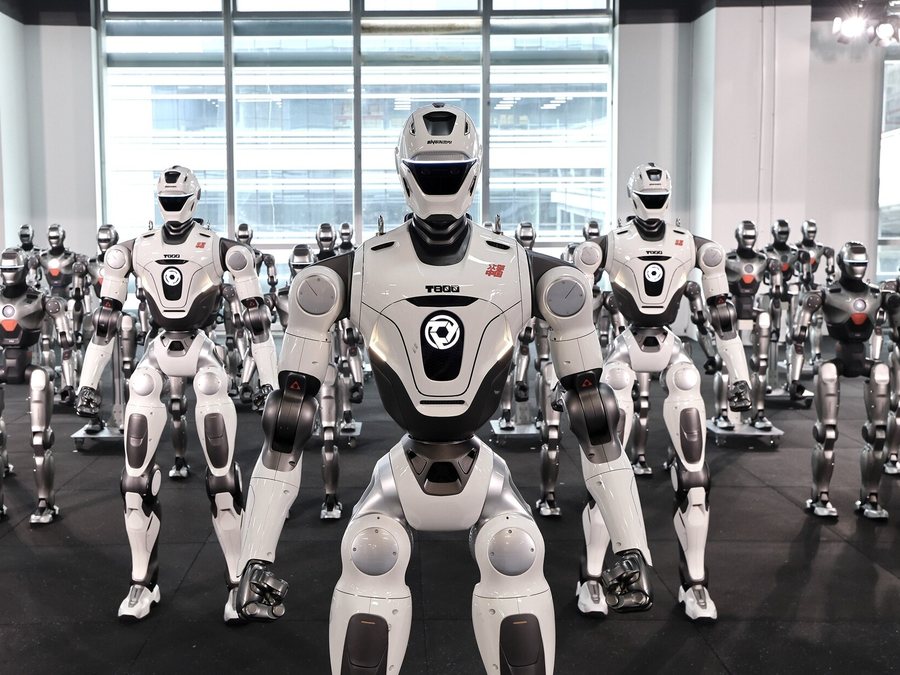
EngineAi T800
Base / Education / Pro · New
- Size173cm (legs 91 cm, arms 60 cm)
- Weight75 (incl. battery, per launch materials)
- DOF25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands)
- Battery / runtime4–5 h (solid-state battery, per manufacturer launch)
- Max speed≥3 m/s (hardware-capable)
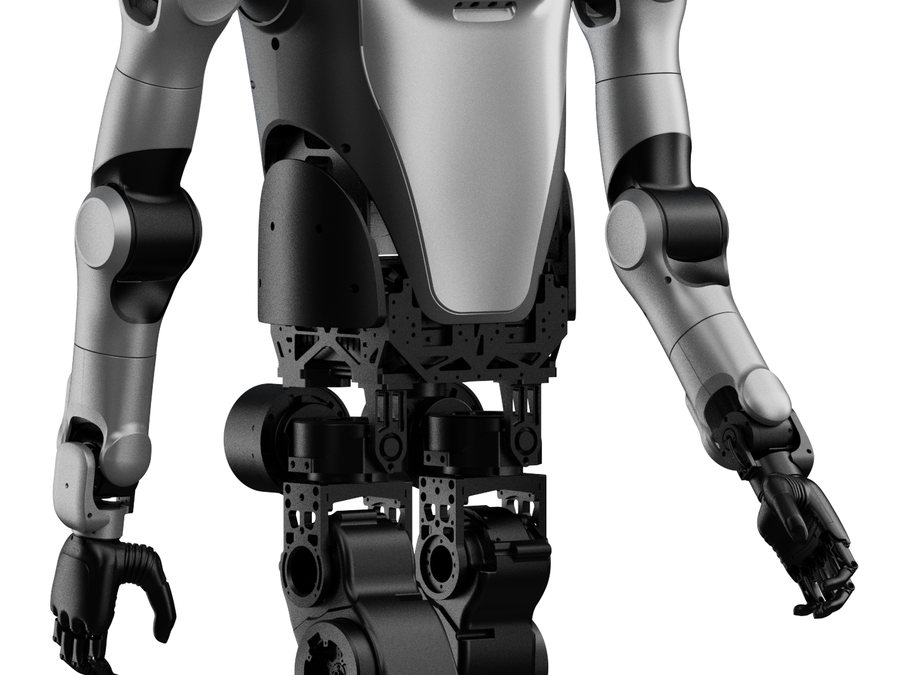
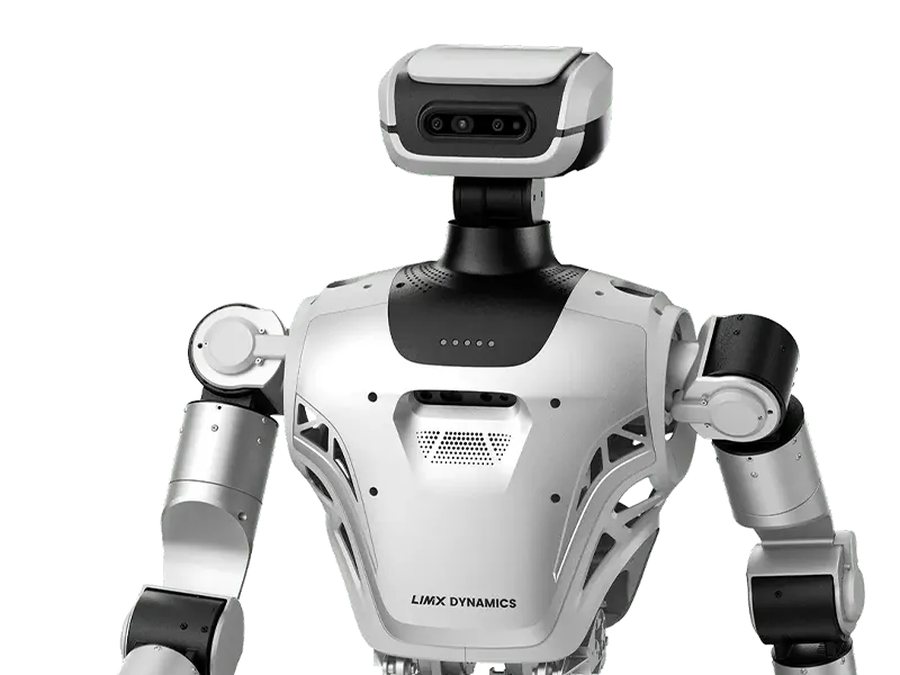
LimX Dynamics Oli
Lite / Edu / Super · New
- Size165cm (shoulder width ≈55 cm, arm length ≈70 cm)
- Weight≤55 (incl. battery)
- DOF31 (body only, excl. end effectors)
- Battery / runtime~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery)
- Max speedMax walking speed 5 km/h
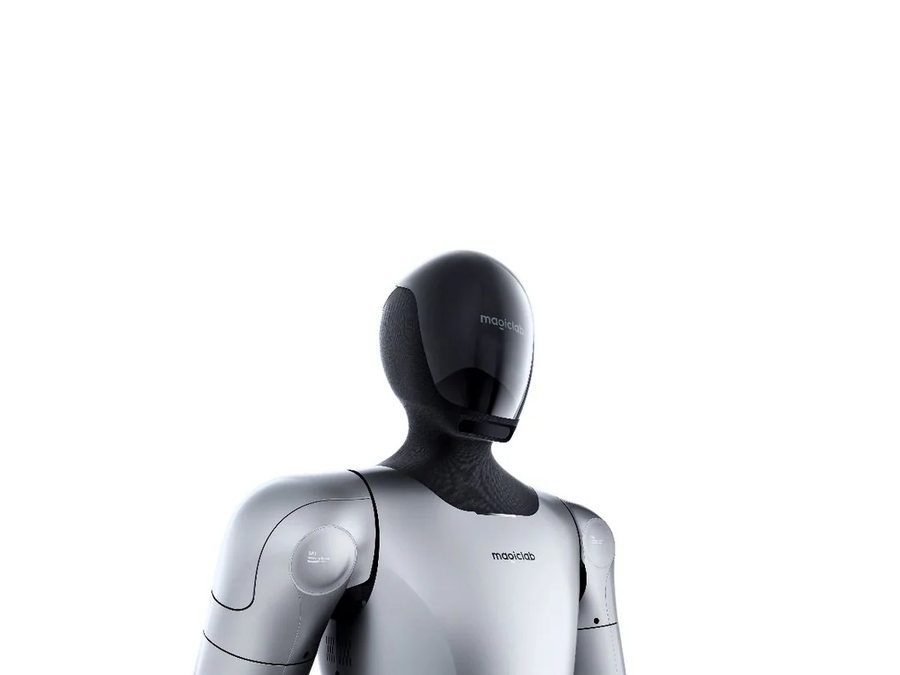
MagicBot Gen1
Base · New
- Size1740×580×280mm (174cm)
- Weight~70 kg
- DOF42 (active DOF)
- Payload7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg)
- Battery / runtime3–5 h (25Ah / 1.35kWh battery)
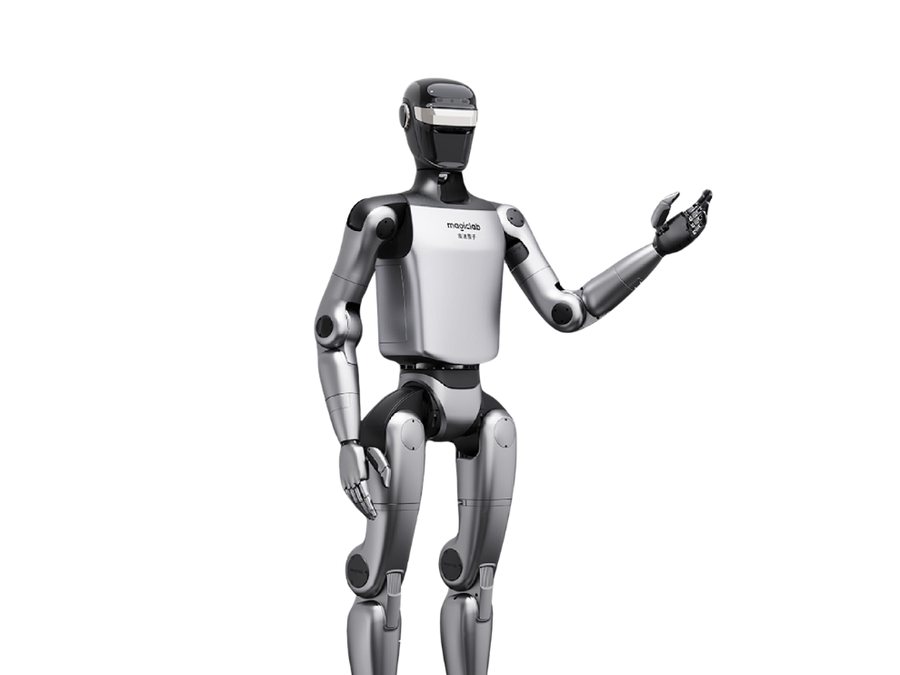
MagicBot Z1
Base · New
- Size~140cm (Developer version 136.9 cm, 1369×422×200 mm)
- Weight~40 (incl. battery)
- DOF24 (base; expandable to 49/50 per different sources)
- PayloadMax 3 kg per arm
- Battery / runtime~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual)
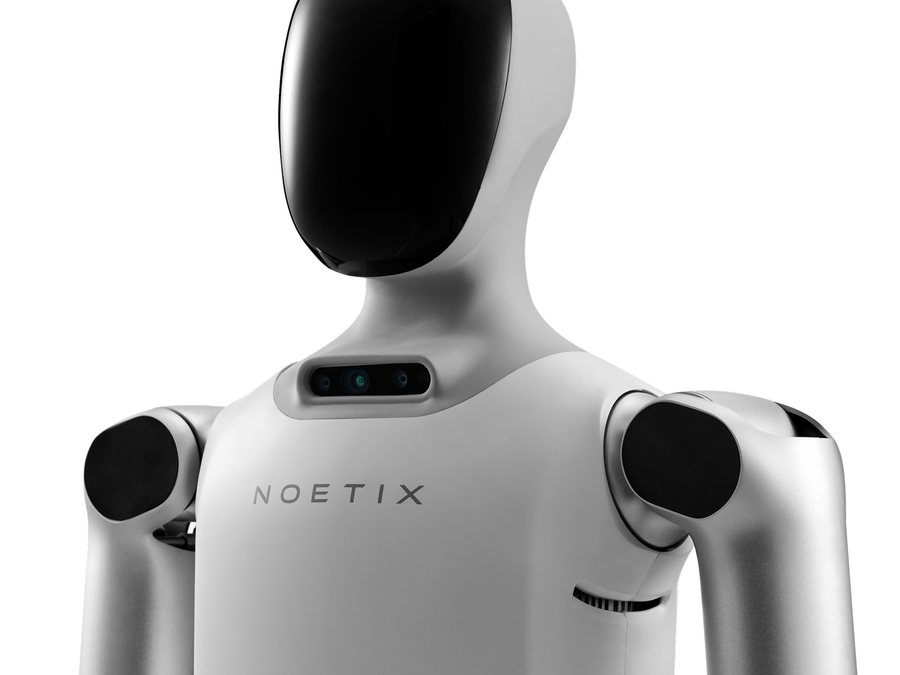
Noteix E1
Standard / Edu · Pre-owned
- Size136×47×29cm
- Weight~36 kg
- DOF23 (manufacturer manual) / 21 (press release) — sources conflict
- Battery / runtime1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict
- Max speedWalking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence)
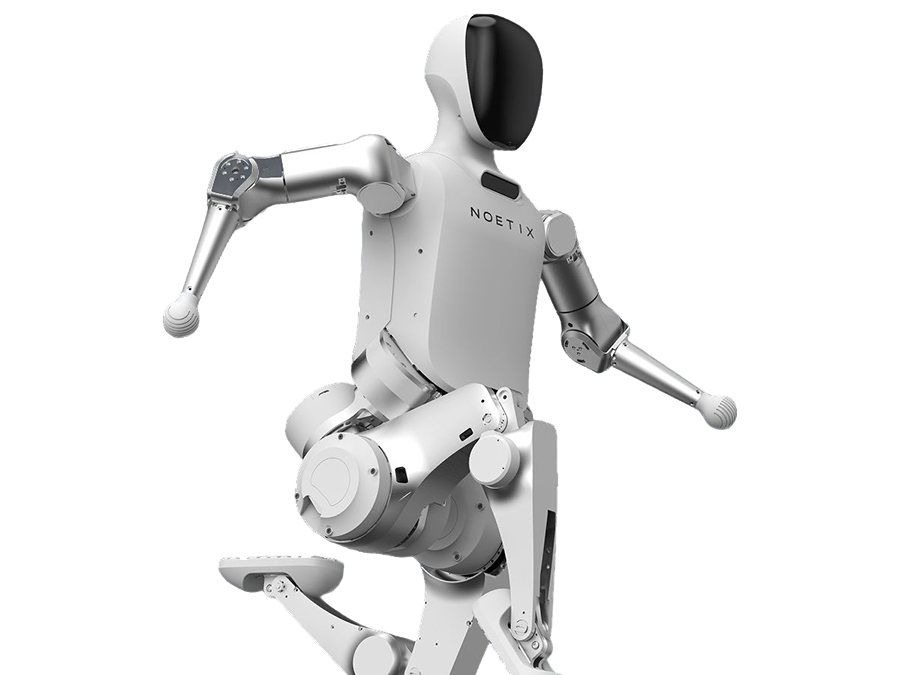
Noteix N2
Standard / Edu · Pre-owned
- Size118 cm H × 47 cm W
- Weight~30 (another compilation lists 29)
- DOF18
- Payload~5 (carried while walking continuously)
- Battery / runtime1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min)
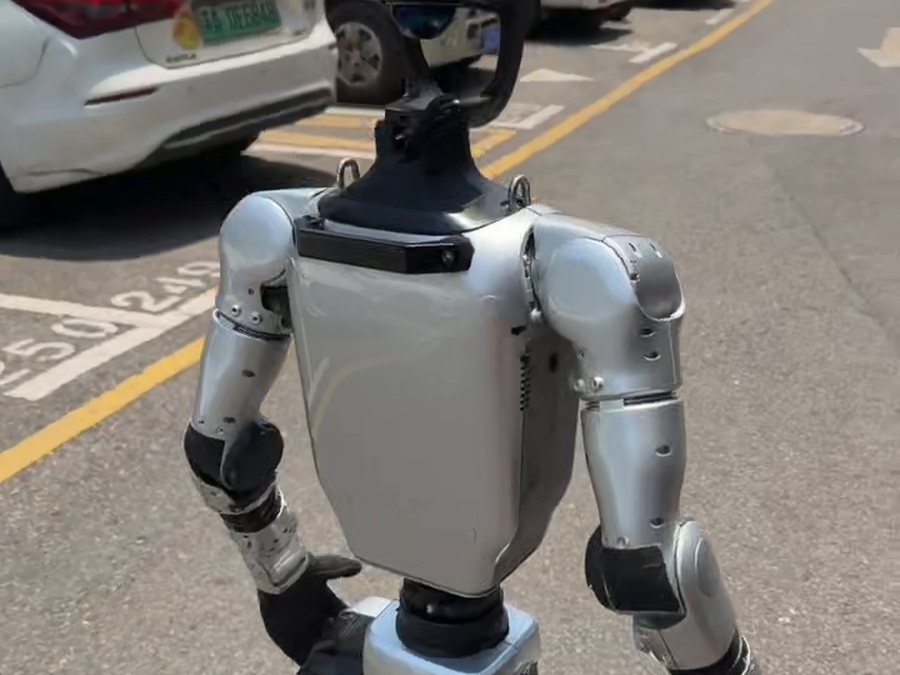
Unitree G1
Basic / U1 / U2 · Pre-owned
- Size1320×450×200mm (Standing )
- Weight35 kg
- DOF23
- Payload~2 (per arm)
- Battery / runtime~2 h
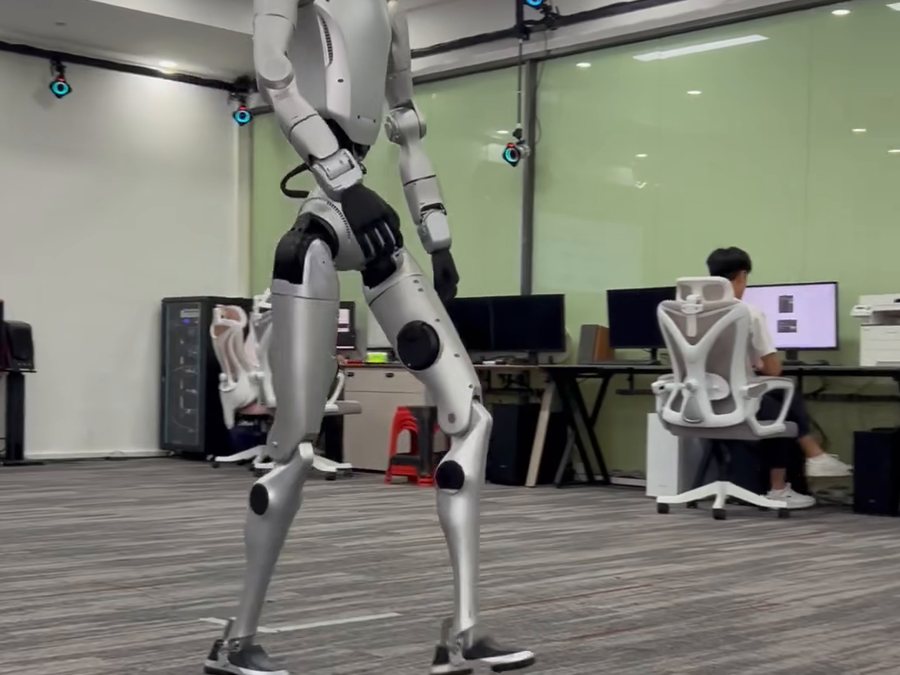
Quadruped robots
Four-legged platforms for research, inspection practice, education and demonstrations — new and pre-owned.
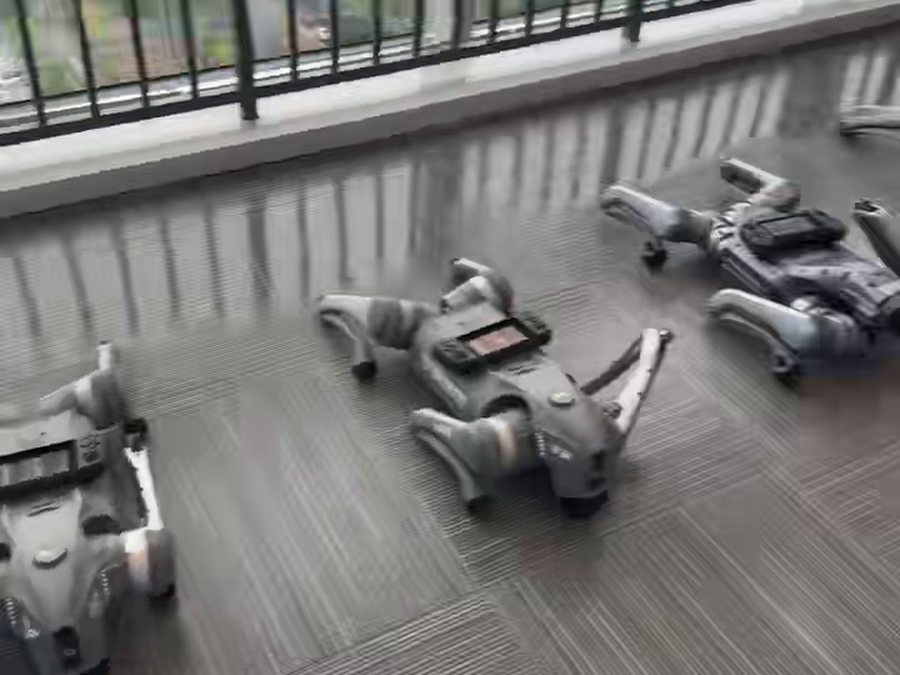
Four-legged robots earn their keep where wheels cannot go: stairs, gravel, grass and broken ground. Our quadruped range runs from compact education platforms to industrial inspection machines, new and pre-owned. If you are not sure which size class you need, tell us the terrain and the payload — that decides it.
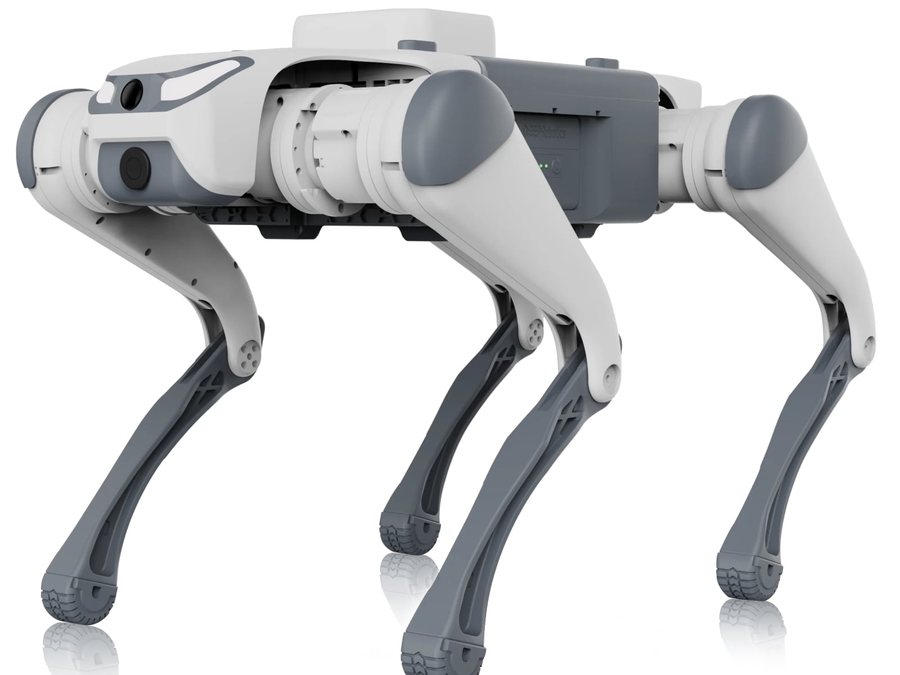
Deep Robotics Lite3
Basic / Venture / Pro / LiDAR · Pre-owned & New
- SizeStanding 610×370×406mm
- Weight12 kg
- DOF12
- PayloadWalking payload 5
- Battery / runtime1.5–2 h
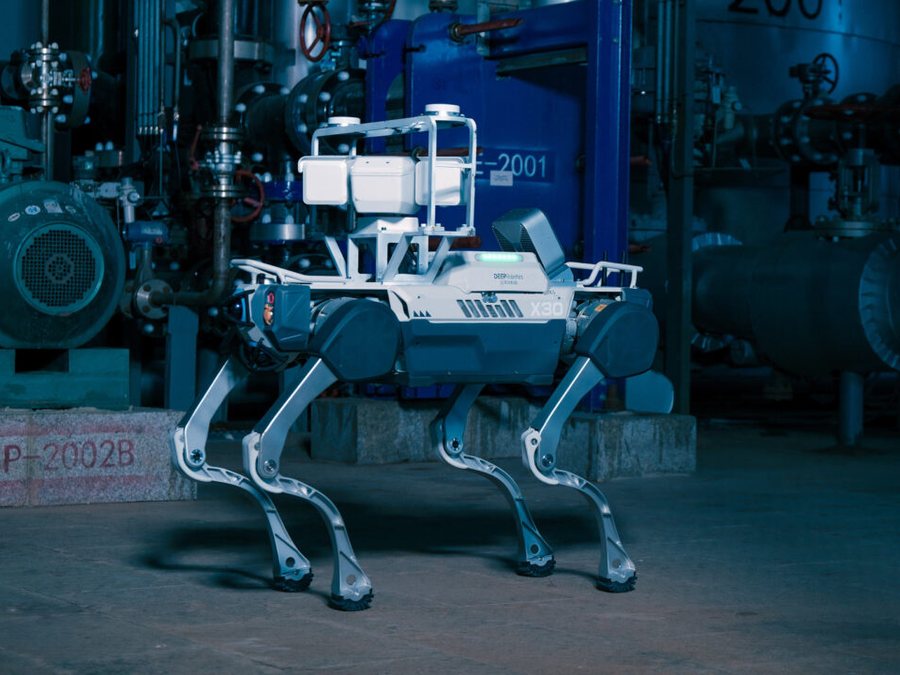
Deep Robotics X30
Basic / Pro · Pre-owned
- SizeStanding 1000×585×470mm
- Weight56 kg
- DOF12
- PayloadRated payload ≥20 (max 85)
- Battery / runtime2.5–4 h
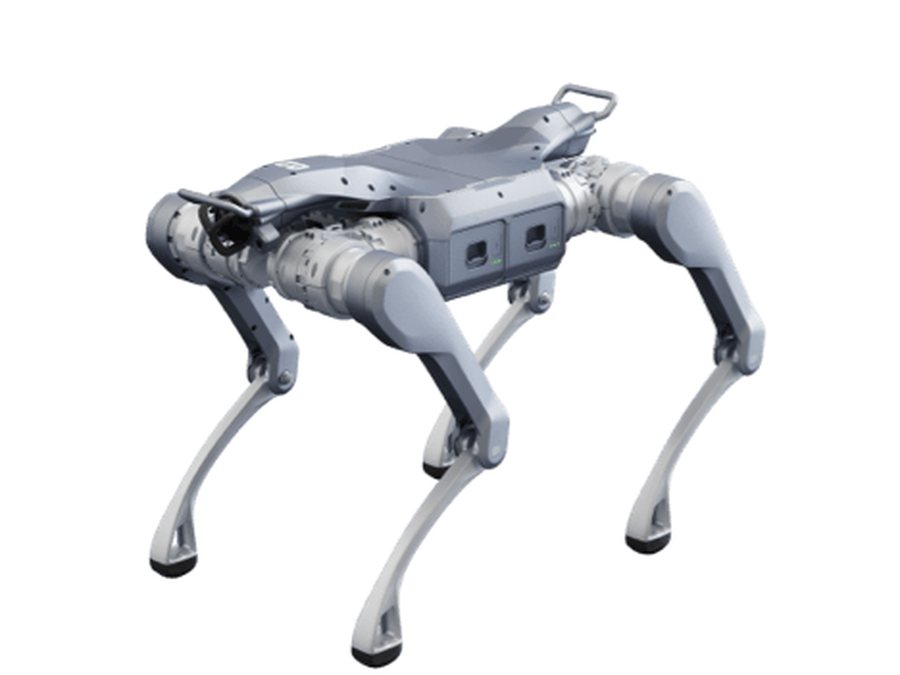
Unitree A2
Base · New
- Size820×440×570mm
- Weight~37 (incl. dual batteries)
- DOF12
- Payload~25 (walking; standing max ~100)
- Battery / runtime~5 h unloaded / ~3 h with 25 kg payload
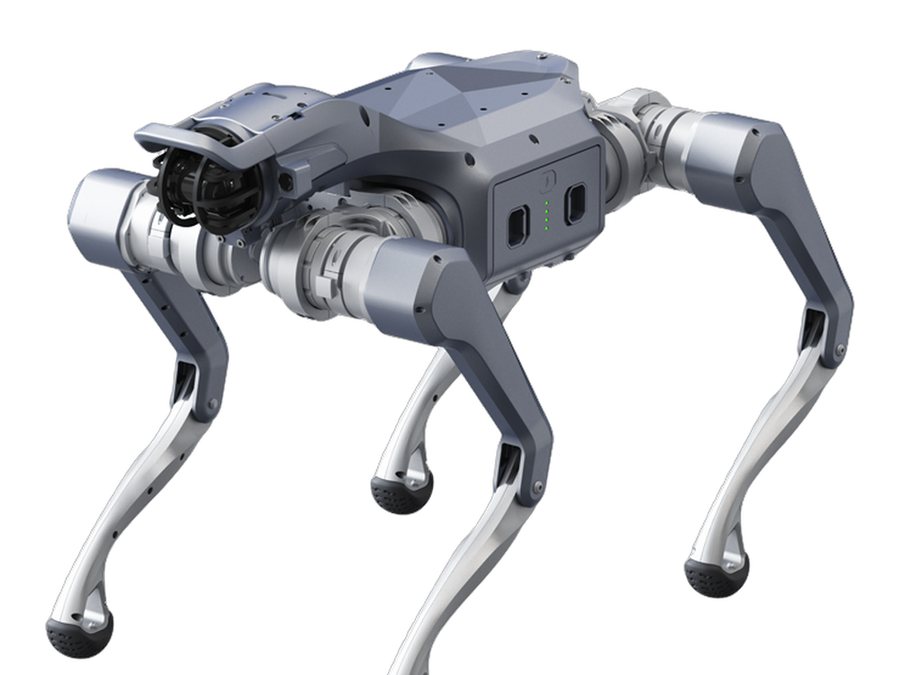
Unitree As2
EDU U1 / EDU U2 / EDU U3 / EDU U4 · New
- Weight18 kg
- DOF12
- Payload~15 (walking; standing max ~65)
- Battery / runtime>4 h unloaded
- Max speed3.7 m/s (peak 5)
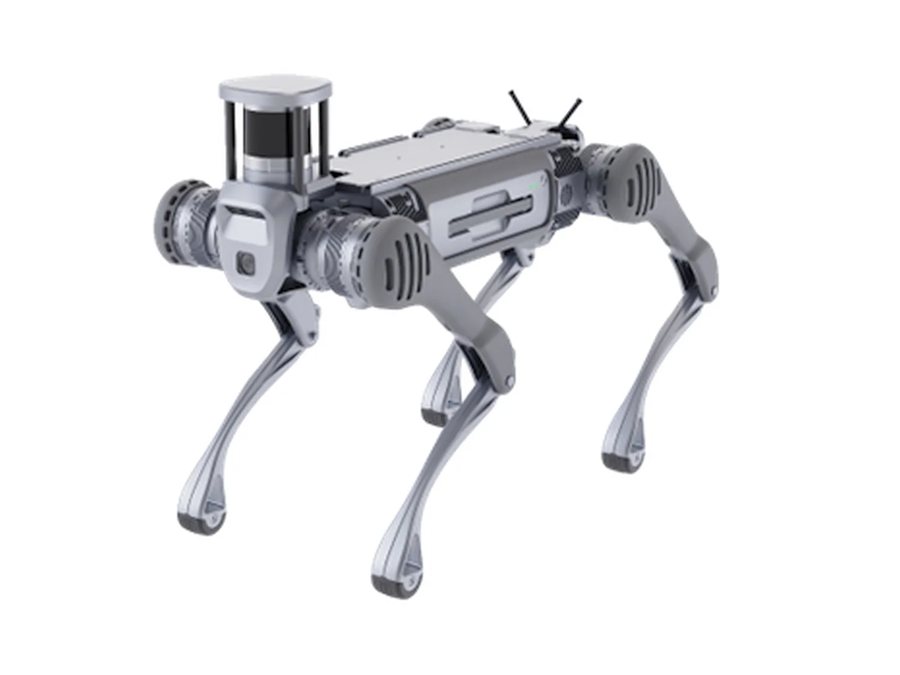
Unitree B2
Base · Pre-owned
- Size~1098×450×645mm
- Weight~60 kg
- DOF12
- PayloadWalking >40 (standing max 120)
- Battery / runtime~4–6 h
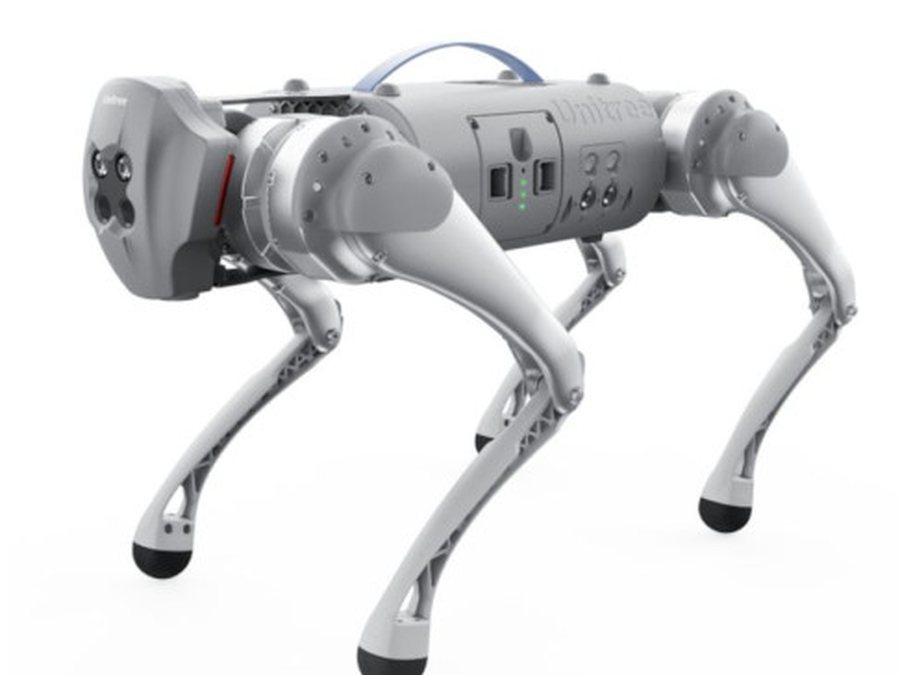
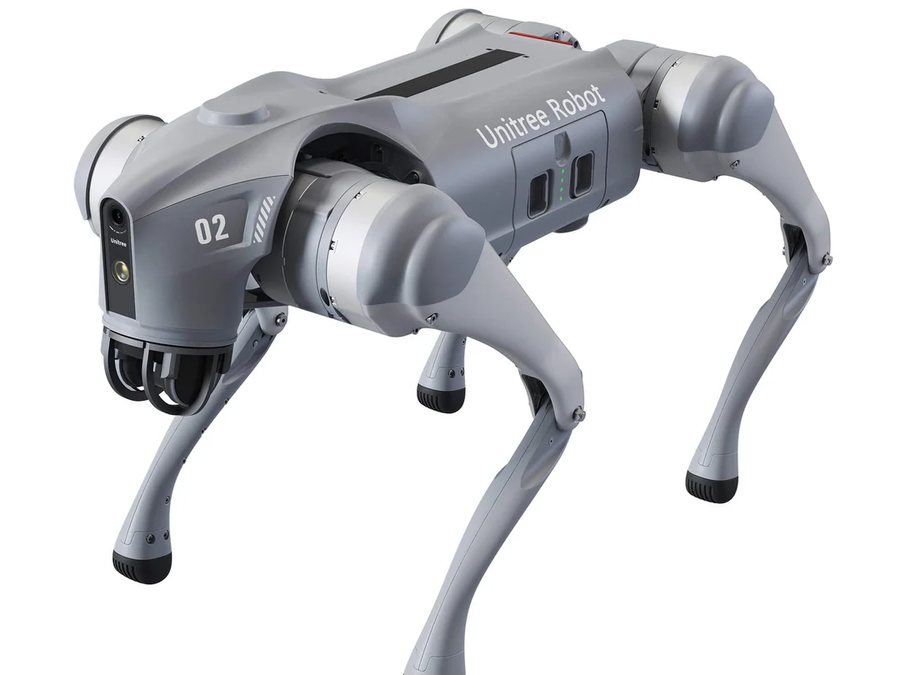
Unitree Go2 Air
Base · Pre-owned
- Size700×310×400mm
- Weight15 kg
- DOF12
- Payload~7 (max ~10)
- Battery / runtime~1–2 h
Unitree Go2 Edu
Base · Pre-owned
- Size700×310×400mm
- Weight15 kg
- DOF12
- Payload~8 (limit 10)
- Battery / runtime~2–4 h (15,000mAh long-life battery)
Unitree Go2 Pro
Base · Pre-owned
- Size700×310×400mm
- Weight15 kg
- DOF12
- Payload~7 (max ~10)
- Battery / runtime~1–2 h
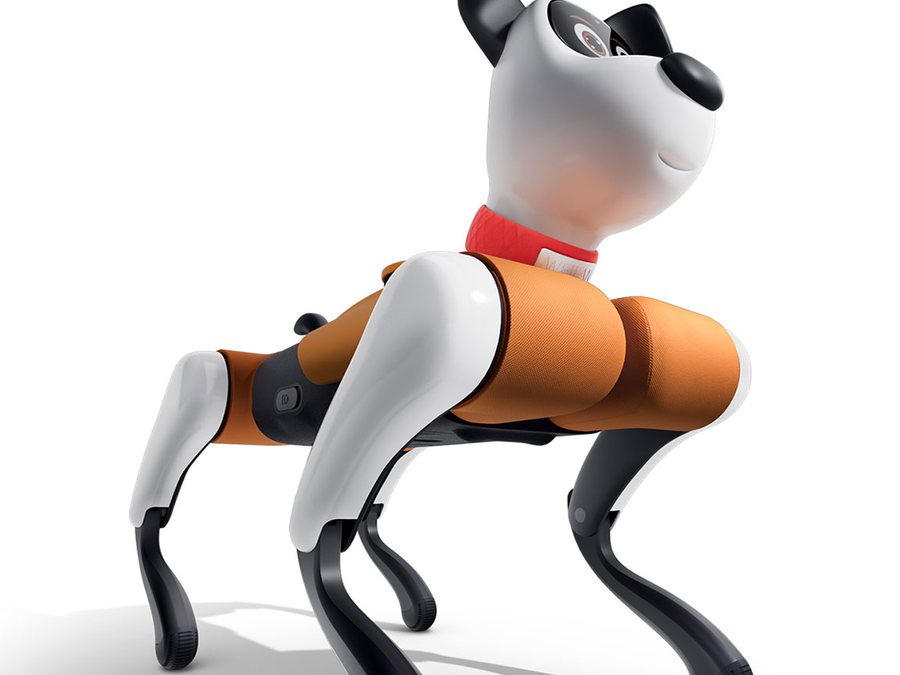
WEILAN Baby Alpha A2
Standard / Plus / Pro / Ultra · Pre-owned
- Battery / runtime~120 min (media report only; not published by manufacturer)
- Max speed6.0 km/h (single media source, low–medium confidence)
Wheeled & wheeled-leg robots
Wheeled-leg quadrupeds that roll on flat ground and step over obstacles — for indoor/outdoor work where wheels alone are not enough.
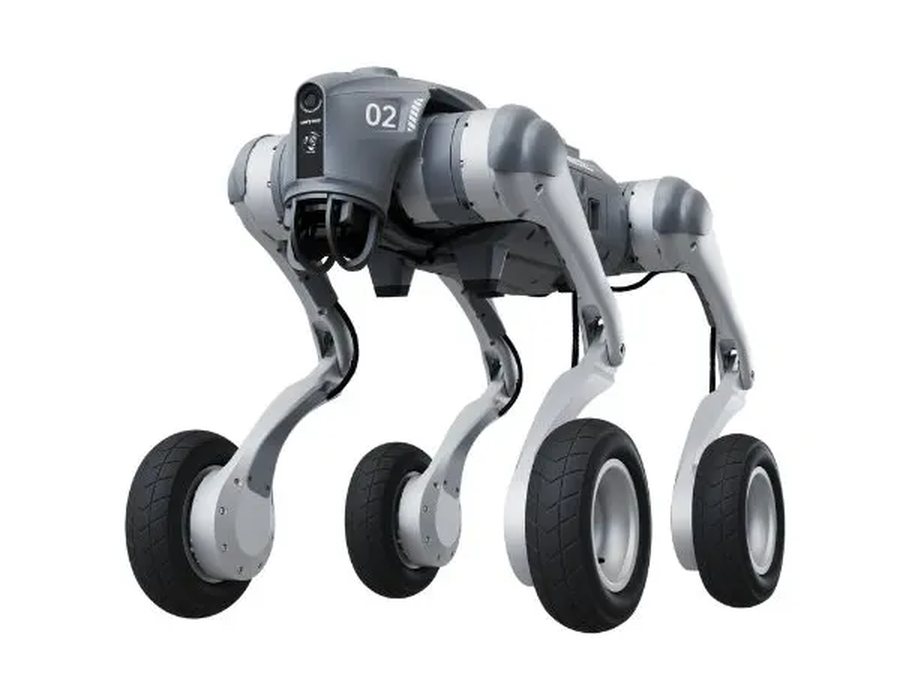
Wheeled and wheeled-leg robots trade a little off-road ability for speed, endurance and stability on the ground most sites actually have — floors, yards, pavements and ramps. This section covers our wheeled-leg quadrupeds; if your site is mostly hard surfaces with the odd step or slope, start here.
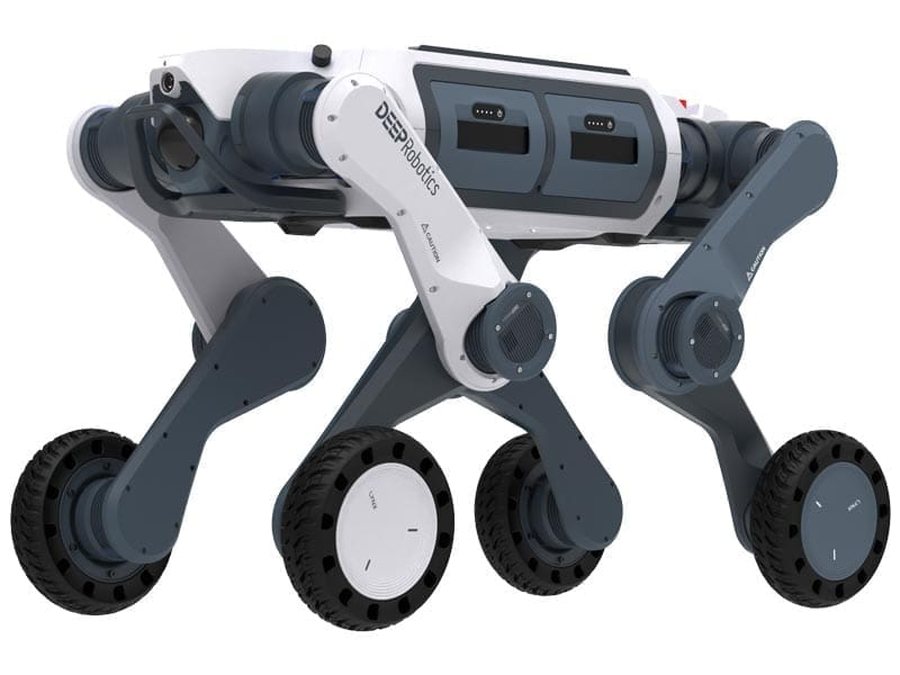
Deep Robotics M20
Basic / Pro · New
- SizeStanding 820×430×570mm
- Weight33 kg
- DOF16
- PayloadRated payload 15 (max 50)
- Battery / runtime3 h unloaded / 2.5 h loaded
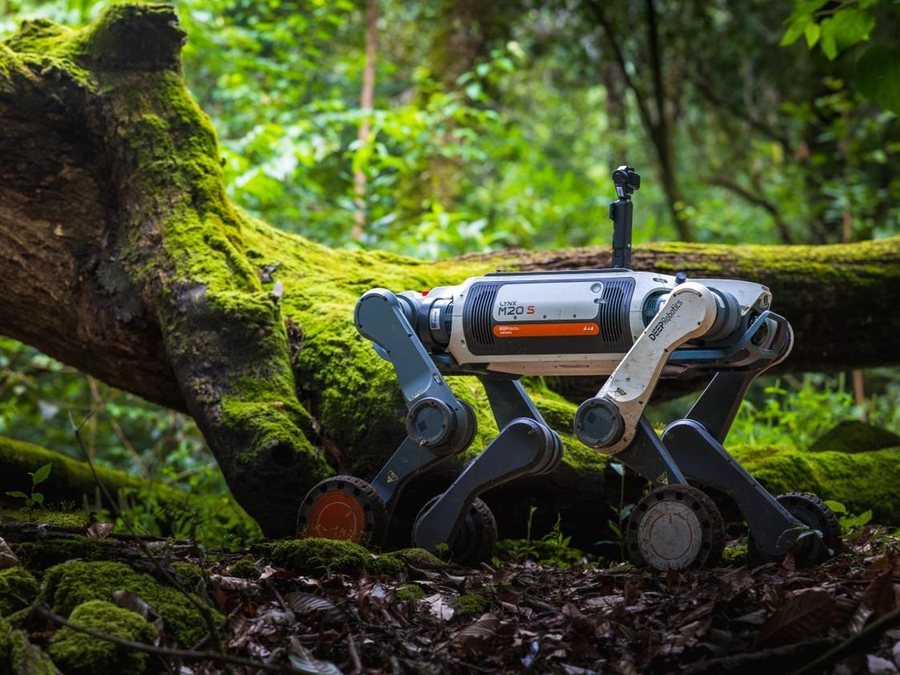
Deep Robotics M20S
New
- Weight33 (manufacturer states weight unchanged from M20 Pro)
- PayloadContinuous payload 35 kg (flat terrain)
- Battery / runtime3.5–5 h unloaded / 2.5–3.5 h loaded
- Max speed9 m/s
Unitree Go2-W
Standard Edition / Smart Edition / Laser Edition · New
- Size700×430×500mm
- Weight18 kg
- DOF16 (12 leg joints + 4 hub motors)
- Payload~8 (max ~12)
- Battery / runtime~2–4 h
Robotic arms
Arms for humanoid and quadruped research platforms, matched to your robot and payload requirements.
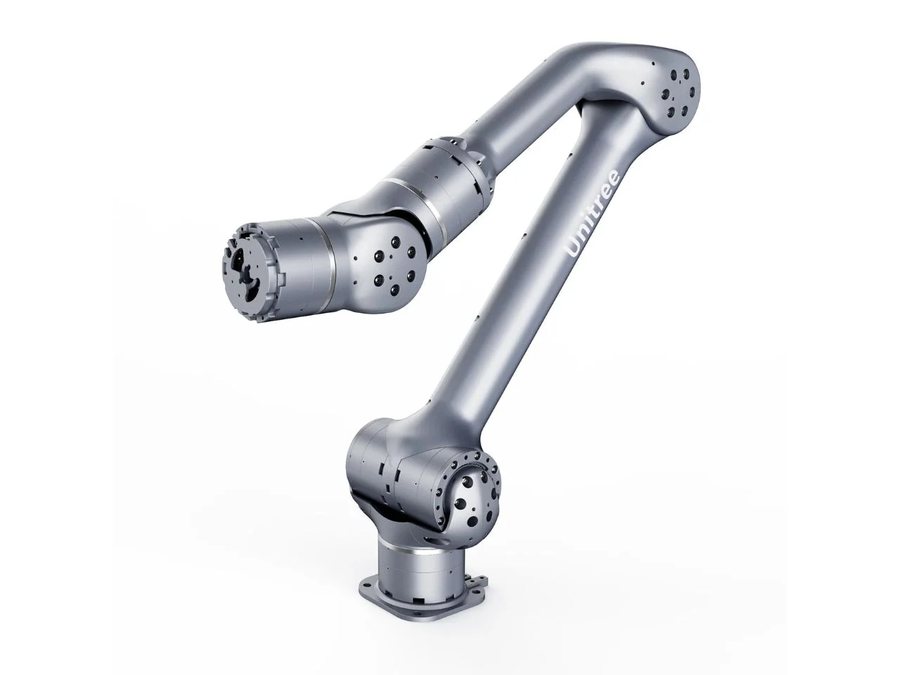
Robotic arms
Tell us the platform you are mounting on and the payload you need — we will match an arm and quote it per specification, together with the robot or on its own.
Pre-owned robots
Pre-owned versions of many models above are in stock — each inspected, with a condition report and a video of the actual unit.
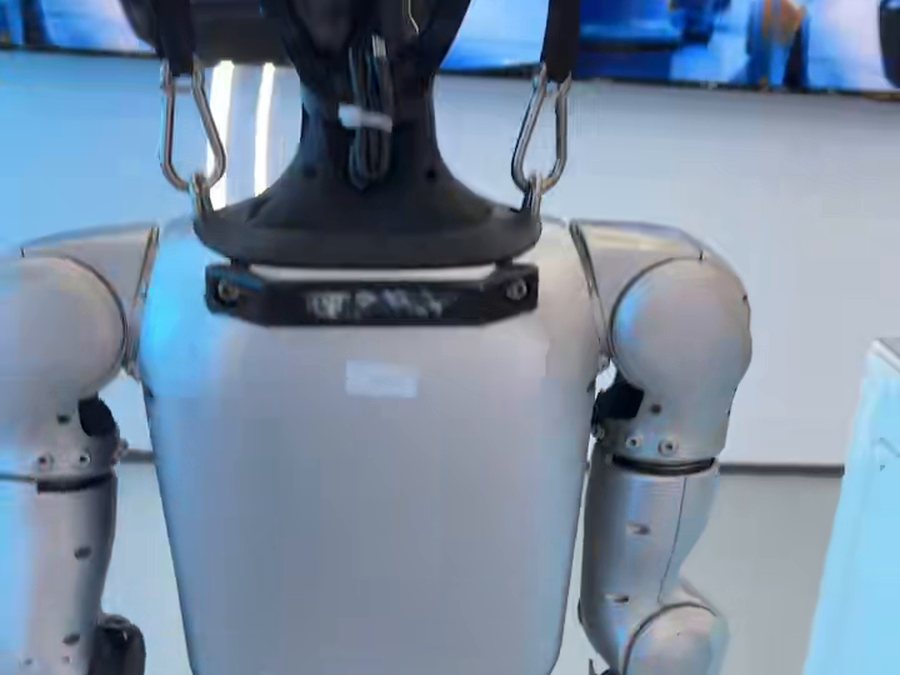
Pre-owned stock
Pre-owned prices are a fraction of the new price for the same model. Tell us the model you are looking for and we will send the condition report and price for the unit in stock.
Parts for Robot Builders
A separate range for teams building their own robots — components, not complete machines.
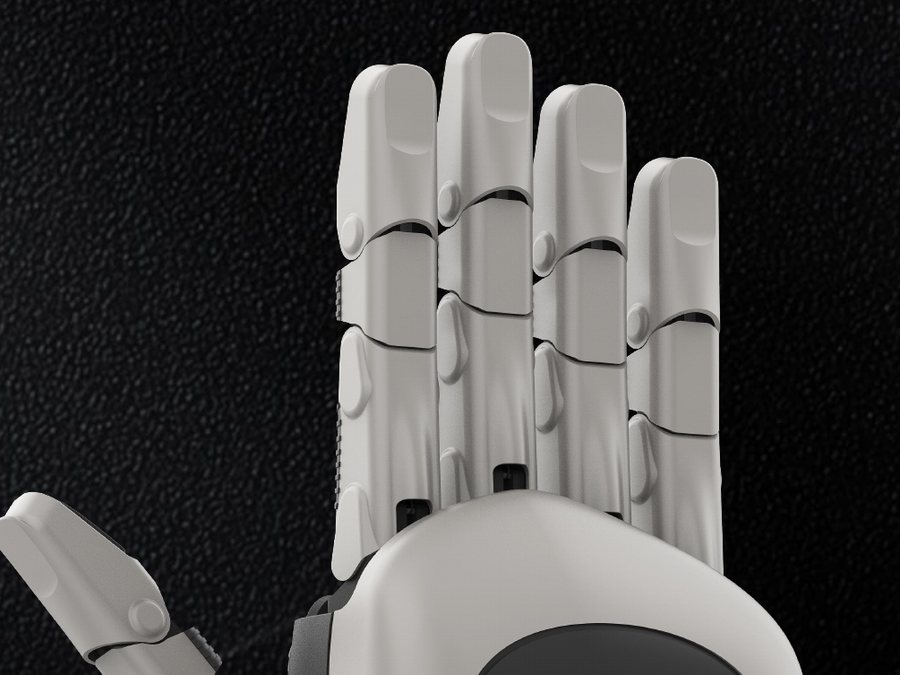
If your team develops its own robots, we also supply the parts that go into them: joint motors and joint modules, dexterous hands — the BrainCo Revo 2 range (Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 per hand, the only list prices in this section) and the Dexrobot DexHand 021 and DexHand 021 S (price to be confirmed) — plus robotic arms, batteries and controllers. Tell us the type, specs and quantity you need — we quote per item.
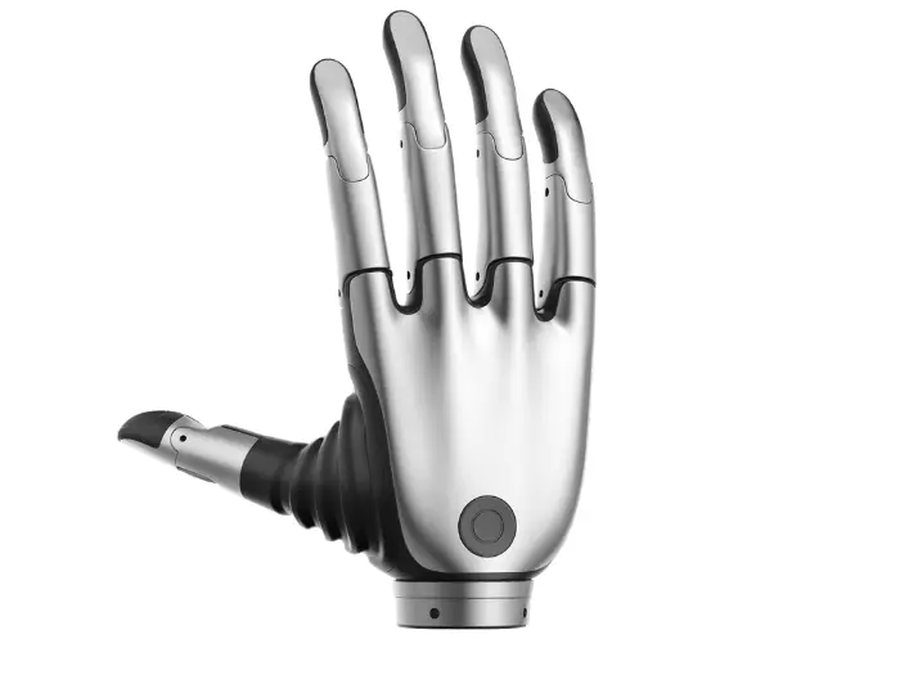
Dexterous hands — Revo 2
Revo 2 series dexterous hands: Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 per hand. Other dexterous hands are also available — send us your specification.
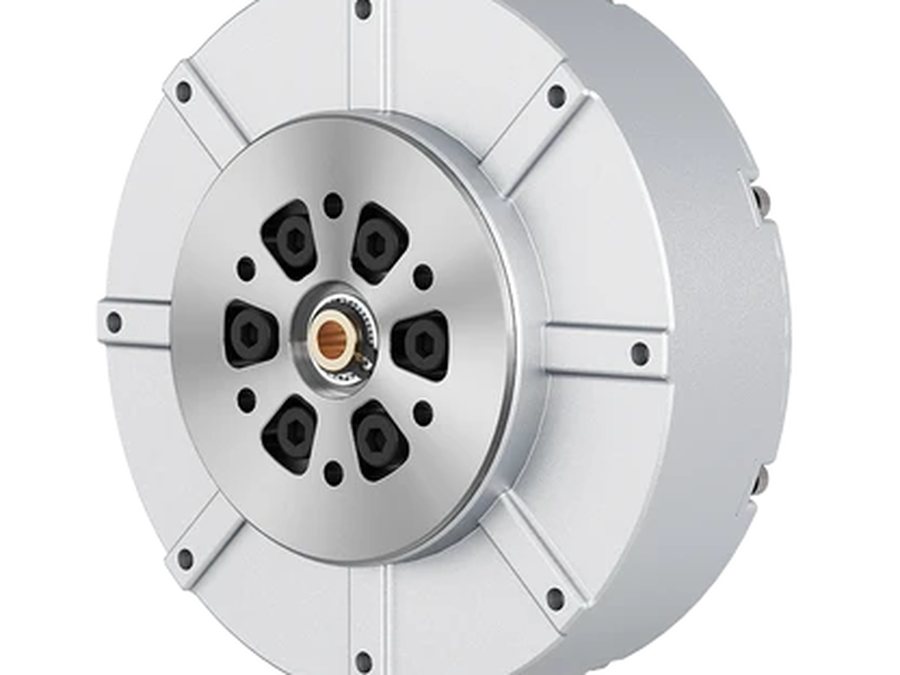
Joint motors & joint modules
Joint motors and joint modules for self-developed robots. Send us the type, specification and quantity you need and we will quote item by item.
Batteries & controllers
Batteries, remote controllers and other accessories for the platforms we supply — priced per specification on request. More parts in our dedicated store: Robosparex — parts & accessories.
Full model list with specifications
All models we currently supply, with key specifications. Condition shows whether the listed version is new or pre-owned; many models are available in both — ask us. You can also download this list (Excel).
| Model | Variant | Condition | Type | Dimensions | Weight (kg) | DOF | Payload (kg) | Battery / Runtime | Max Speed | Development Support |
|---|---|---|---|---|---|---|---|---|---|---|
| AgiBot A2 | Young Edition | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 63 | 23 | ~2 kg per arm | Battery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet) | Max walking 0.8 m/s (dealer spec sheet) | AimMaster/AimDK choreography and interaction customization tools (performance & presentation use); full low-level SDK openness not clearly stated by the manufacturer |
| AgiBot A2 | Flagship | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 69 | 40+ (active DOF) | ~3 kg per arm | 700Wh; ~2 h (hot-swappable battery) | Max walking 1.2 m/s (after V1.3 OTA update) | Secondary development supported: AimDK (HTTP JSON-RPC + ROS2 Topic interfaces, AimRT framework) |
| AgiBot X2 | Basic Version | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 35 | 25 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh; ~2 h continuous walking (at 0.5 m/s) | 1.8m/s | No secondary development (no public SDK, locked system; development open on Ultra only) |
| AgiBot X2 | Ultra | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) |
| AgiBot X2 | Ultra | Used | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking (pre-owned unit; hardware identical to new) | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) (pre-owned unit; hardware identical to new) |
| AgiBot A3 | Basic Version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (AimDK development only on the Development version) |
| AgiBot A3 | Development version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open AimDK development SDK (HTTP JSON-RPC + ROS2 Topic interfaces) |
| AgiBot A3 Ultra | Basic Version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (Open SDK + ROS2 only on Development/EDU versions) |
| AgiBot A3 Ultra | Development version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK), full development documentation included |
| AgiBot A3 Ultra | Embodied version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | No separate official statement found on this version's software entitlements (hardware as A3 Ultra) |
| AgiBot A3 Ultra | EDU | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK); education/research software and support package |
| Booster K1 | Geek | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 2Ah; ~20 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (this version: 48 TOPS compute) |
| Booster K1 | Education | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~80 min | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (117 TOPS, Jetson Orin NX) |
| Booster K1 | Professional | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~70 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (200 TOPS, Jetson AGX Orin) |
| Booster T1 | Basic | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); no Intel host on this version (AGX Orin 200 TOPS only). Note: one third-party database claims the Basic version lacks SDK support, contradicting official developer docs — confirm with the manufacturer before ordering |
| Booster T1 | Standard | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); AGX Orin 200 TOPS + Intel i7-1370P host |
| Booster T1 | Customized | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 31 (gripper version) / 41 (dexterous-hand version) | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); 7-DOF arms, optional gripper or 6-DOF dexterous hands; compute as Standard |
| Booster T2 | P1 | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (base configuration, no end effector) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P2 Claw | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (standard gripper configuration) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P3 Nimble Hands | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (6-DOF dexterous hands) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Deep Robotics Lite3 | Basic | New | Quadruped | Standing 610×370×406mm | 12 | 12 | Walking payload 5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Venture | Used | Quadruped | Standing 610×370×445mm | 12.2 | 12 | Walking payload 4.5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Pro | Used | Quadruped | Standing 610×370×450mm | 12.9 | 12 | Walking payload 4 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | LiDAR | Used | Quadruped | Standing 610×370×496mm | 13.5 | 12 | Walking payload 2.5 | 1.5–2 h | 4 m/s | Motion control SDK, perception development sample code and communication protocols (ROS1/ROS2) |
| Deep Robotics M20 | Basic | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Business development interfaces (Gigabit Ethernet, 72V power interface) |
| Deep Robotics M20 | Pro | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Secondary development supported (Gigabit Ethernet, USB 3.0, 24V/72V power interfaces, SLAM mapping & navigation) |
| Deep Robotics X30 | Basic | Used | Quadruped | Standing 1000×585×470mm | 56 | 12 | Rated payload ≥20 (max 85) | 2.5–4 h | ≥4 m/s | Secondary development supported |
| Deep Robotics X30 | Pro | Used | Quadruped | Standing 1000×585×470mm | 59 | 12 | 20 (max 85) | 4 h unloaded / 2.5 h loaded | ≥4 m/s | Secondary development supported (industrial-grade SDK interfaces) |
| Deep Robotics M20S | — | New | Quadruped (wheeled-leg) | Not published | 33 (manufacturer states weight unchanged from M20 Pro) | Not published | Continuous payload 35 kg (flat terrain) | 3.5–5 h unloaded / 2.5–3.5 h loaded | 9 m/s | Not published |
| Dobot Atom | Base | New | Humanoid | Height ~1530mm | 62 | 41 (incl. dexterous hands; 29 without hands) | 3.5 kg per arm | ~2 h | 1.5 m/s (walking) | SDK secondary development supported (official SDK development guide available) |
| EngineAi PM01 | Commercial | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | No secondary development (manufacturer manual lists openness as "not supported"); the manufacturer also publishes EngineAI ROS (ROS2-based) open resources |
| EngineAi PM01 | Education | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | Open platform: x86 + NVIDIA Jetson Orin dual chips, open training/deployment code, secondary development supported; ROS2 (EngineAI ROS framework); native SDK (pm01_edu) via GitHub mirror, not directly from the official site |
| EngineAi T800 | Base | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery, per launch materials) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | No secondary development |
| EngineAi T800 | Education | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery; dealers cite 75–85 depending on version) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported (official Eco/open-source edition ≈ this Education version: stereo vision/LiDAR + AGX Orin 64G); dedicated official T800 SDK documentation not found |
| EngineAi T800 | Pro | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75–85 (varies by version, per dealers) | 43 (29 body + 7×2 hands) | Dexterous hand 5 kg per hand (whole-body / per-arm payload not published) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported |
| Leju Robotics Kuavo 4Pro | Base | New | Humanoid | Height ~1660mm | 55 | 40+ | Not published | Not published | >7 km/h (running) | Fully open motion-control and application development interfaces (open-source HarmonyOS) |
| LimX Dynamics Oli | Lite | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors) | Not published (same-series EDU/Super: max 3 kg per arm; no per-variant data for Lite) | ~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| LimX Dynamics Oli | Edu | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors; RobotShop lists 33 — unconfirmed) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development (plus C++/JavaScript examples); ROS2 (official GitHub); Isaac Sim/MuJoCo/Gazebo support |
| LimX Dynamics Oli | Super | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 33 (body only, excl. end effectors) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| Noteix N2 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | No secondary development; no official ROS2/Python statement found |
| Noteix N2 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | Secondary development supported (adds NVIDIA Jetson Orin Nano Super compute, depth camera; optional spherical hands / five-finger hands); no official ROS2/Python statement found |
| Noteix E1 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Base compute 6 TOPS (RK3588s); no open-SDK statement found; no official ROS2/Python statement found |
| Noteix E1 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Open SDK interfaces (velocity/motion commands and joint-level algorithm control), 6+67 TOPS compute (adds Jetson Orin Nano Super, depth camera); no official ROS2/Python statement found |
| Unitree G1 | Basic | Used | Humanoid | 1320×450×200mm (Standing ) | 35 | 23 | ~2 (per arm) | ~2 h | 2 m/s | No secondary development (no SDK; remote control / app demos only) |
| Unitree G1 | U1 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Jetson Orin compute module) |
| Unitree G1 | U2 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 (expandable) | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Orin NX 100 TOPS) |
| Unitree H2 | Basic | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | No official secondary-development support found (only the EDU version explicitly supports it) |
| Unitree H2 | EDU | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | Secondary development supported (EDU version; compute module customizable) |
| Unitree Go1 Air | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1 h | 2.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go1 Pro | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1.5 h | 3.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go2 Air | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 2.5 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Pro | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 3.7 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Edu | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~8 (limit 10) | ~2–4 h (15,000mAh long-life battery) | 3.7 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python; optional Jetson Orin expansion dock) |
| Unitree Go2-W | Standard Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Smart Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Laser Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree A2 | Base | New | Quadruped | 820×440×570mm | ~37 (incl. dual batteries) | 12 | ~25 (walking; standing max ~100) | ~5 h unloaded / ~3 h with 25 kg payload | 3.7 m/s (up to ~5) | Secondary development supported (Intel i7 development compute, ROS/ROS2) |
| Unitree As2 | EDU U1 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U2 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U3 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U4 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree B2 | Base | Used | Quadruped | ~1098×450×645mm | ~60 | 12 | Walking >40 (standing max 120) | ~4–6 h | >6 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python) |
| WEILAN Baby Alpha A2 | Standard | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 128GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Plus | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 256GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Pro | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 512GB storage, Premium Orange) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Ultra | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 1TB storage, Cyber Dream) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| MagicBot Z1 | Base | New | Bipedal humanoid (compact, high-dynamic; not a quadruped — the quadruped line is MagicDog) | ~140cm (Developer version 136.9 cm, 1369×422×200 mm) | ~40 (incl. battery) | 24 (base; expandable to 49/50 per different sources) | Max 3 kg per arm | ~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual) | ≥2.5m/s | Secondary development / OTA supported; official SDK magicbot-z1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
| MagicBot Gen1 | Base | New | Full-size general-purpose humanoid (nicknamed "Xiaomai") | 1740×580×280mm (174cm) | ~70 | 42 (active DOF) | 7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg) | 3–5 h (25Ah / 1.35kWh battery) | Official site ≥4 km/h; manual ≥2 m/s — sources differ | Secondary development / OTA supported; official SDK magicbot-gen1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
Found your model?
Tell us the model and quantity — we confirm price, stock and lead time, usually within 24 hours.
Request a quote